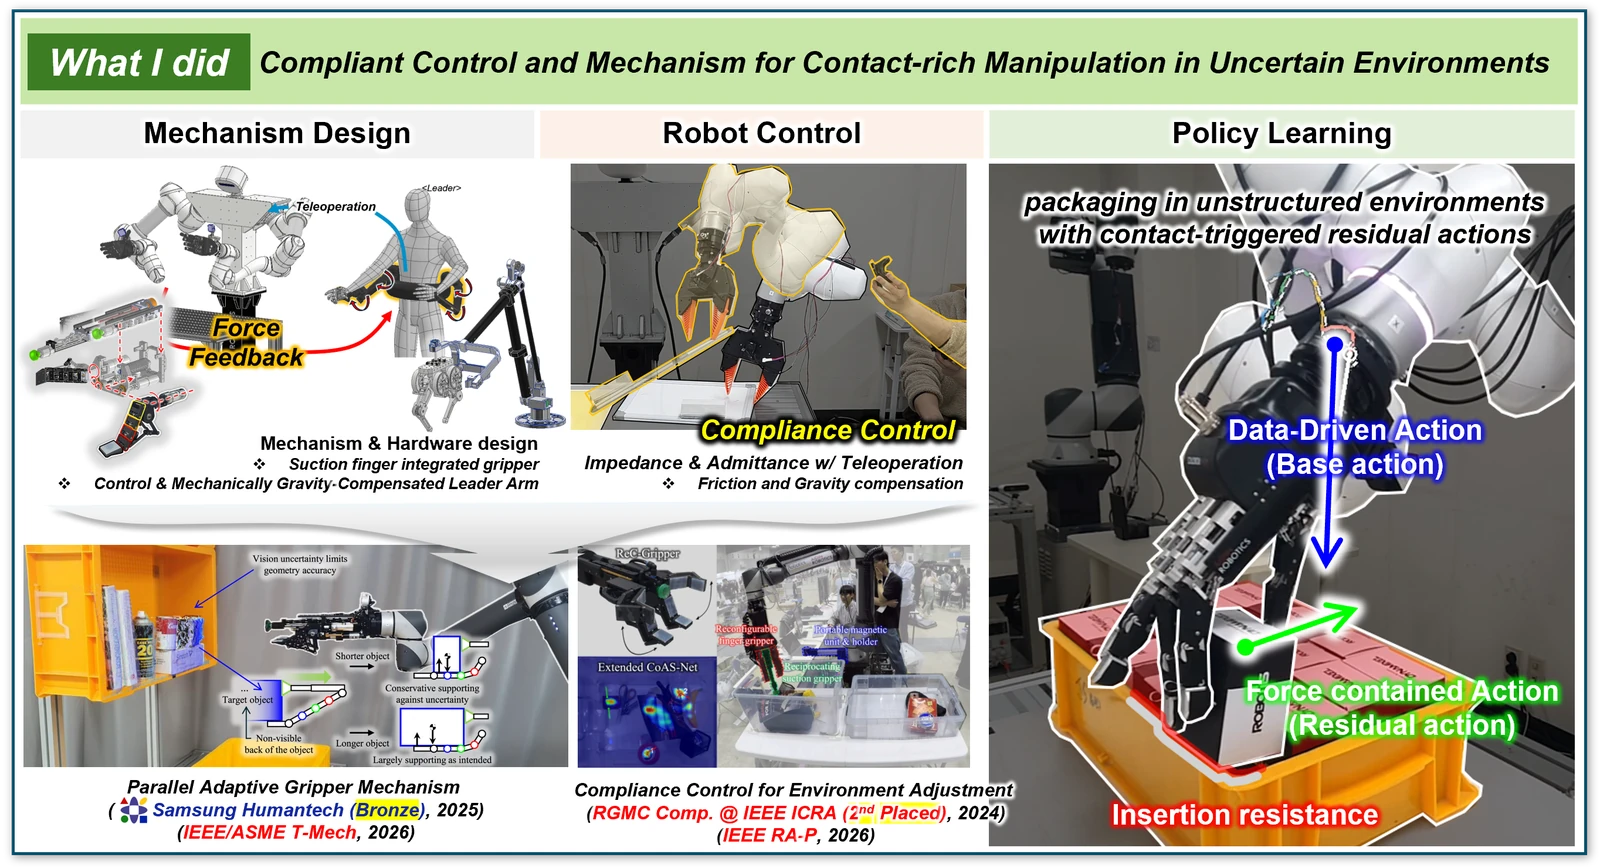
My research focuses on contact-rich robotic manipulation,
connecting physically intelligent gripper design, compliant control, and robot learning.
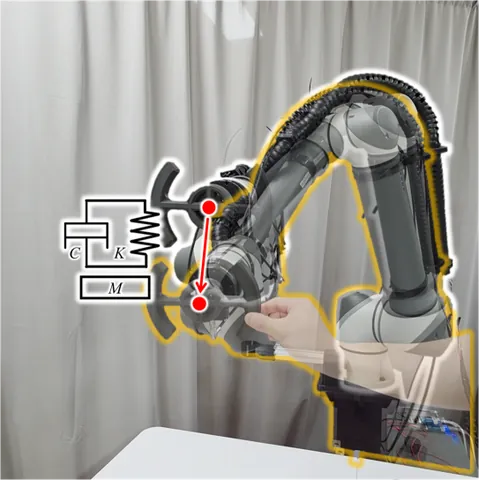
My recent work explores force-feedback teleoperation, imitation and reinforcement
learning for robotic hands, and improving manipulation policies through human corrections.
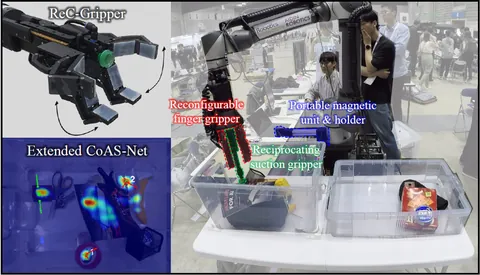
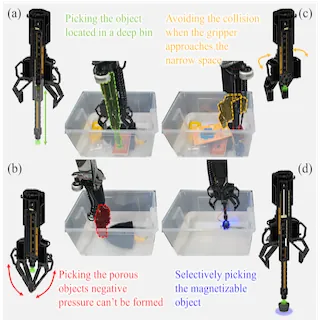
To address the limitations of single-modality grasping in complex environments, we present a robust
network and compliance control validated for industrial applicability at the ICRA 2024 RGMC.
This work achieved 2nd place at the
9th RGMC 2024 and was invited to publish in the RA-P Special Collection on
"Autonomous Robotic Grasping and Manipulation in Real-World Applications".
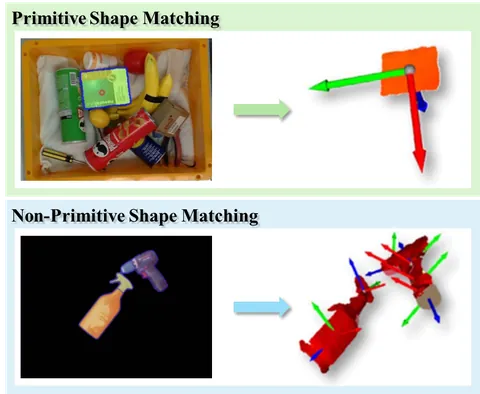
Training-free, plug-and-play module that enhances existing grasp planners for unknown objects.
It reorganizes the grasp candidates based on an object's centroid from a single RGB-D image.
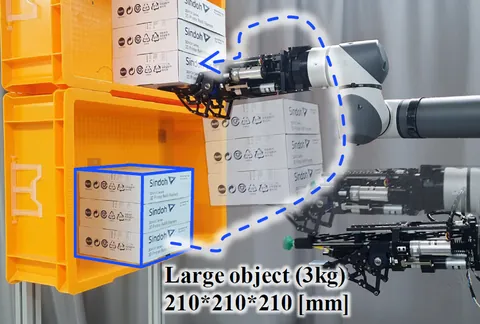
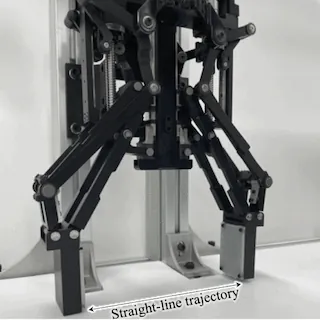
Gripper design that applies a Grasshopper mechanism to improve fingertip movement. It also allows
the fingertips to move towards the palm of the gripper after grasping an object, thereby expanding
the range of object sizes that can be adaptively grasped.
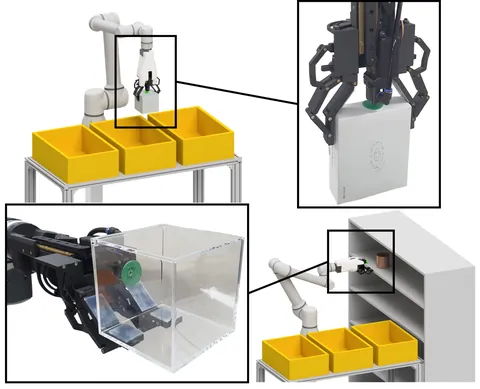
Reconfigurable gripper that handles objects in both bin and shelf environments.
Its performance was validated in shelf experiments and in a competition-style bin environment.
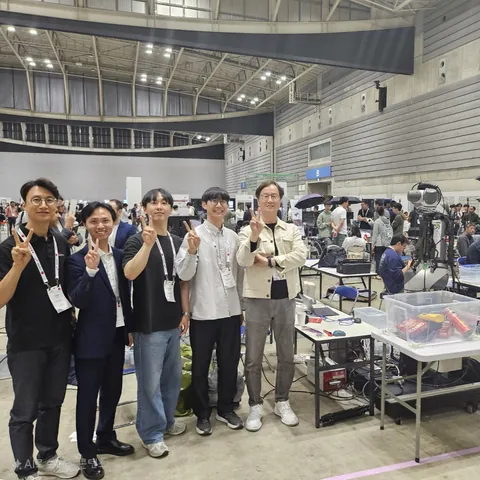
Competed in the 9th Robotic Grasping and Manipulation Competition (RGMC) at ICRA 2024
with ReC-Gripper and
an extended CoAS-Net.
🏆 Best Prizein the Contest 3D Design for the Future, Ministry of Trade, Industry and Energy (MOTIE),
2023
🥉 Bronze Prizein the Competition The Korean Society of Mechanical Engineers (KSME), 2021
🏵️ Encouragement Prizein the Contest Creative and Intelligent Robot Contest (CIRO), 2021
[1st Team]
Seunghwan Um,
Hyungjin Park,
Jaehyeon Nam,
Boseok Kim,
Yohan Ahn,
Minsu Kong,
Changho Lee,
Hyunju Kwak,
Joonmyung Choi*
[2nd Team]
Boseok Hong,
Youngsu Jeong,
Euichan Kim
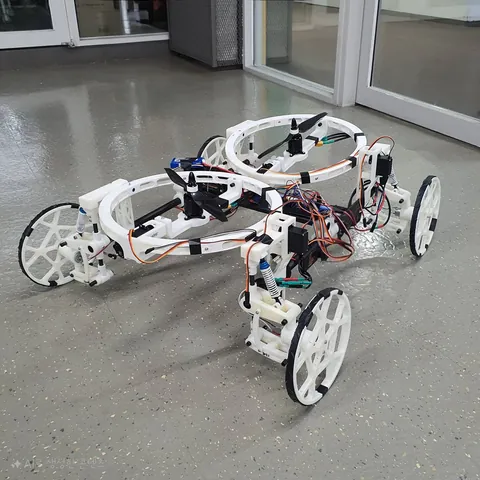
Team leader of Wall Climbing Car (WCC)[Undergraduate Project]
Disney Research's VertiGo looked like so much fun at the time that we tried building our own
version at an undergraduate level.
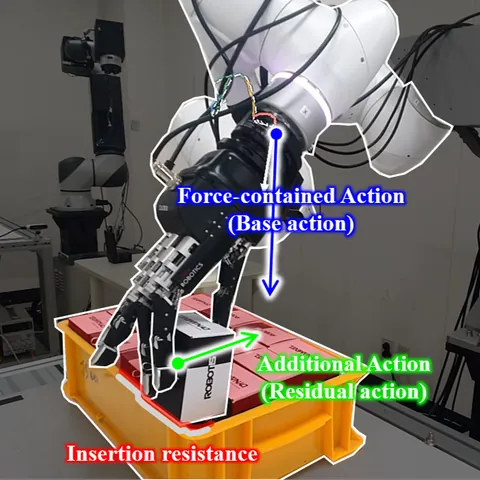
Human-guided residual learning for contact-rich box insertion. A frozen base policy is corrected
at the Original position and an unseen backward target shift of 3 cm.
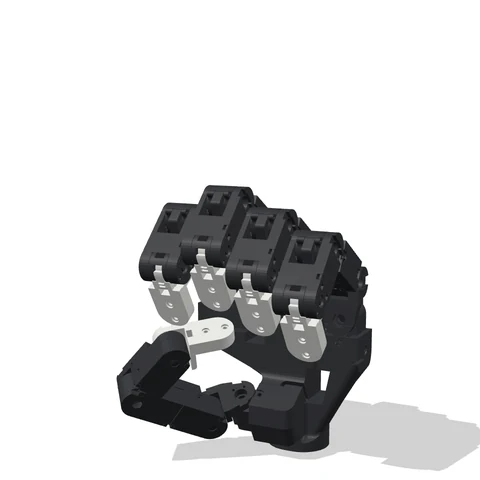
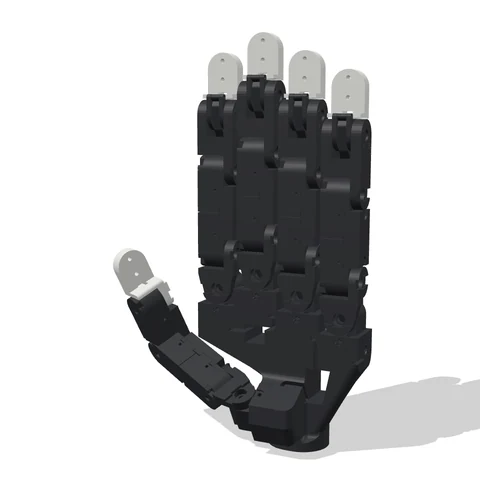
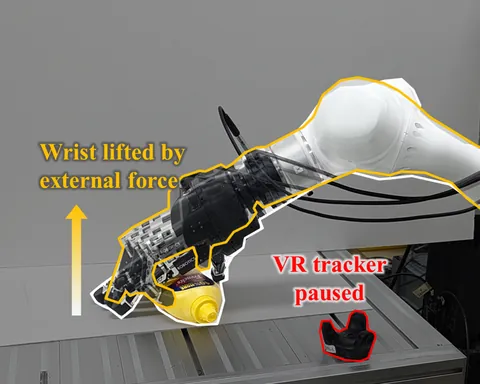
Imitation and reinforcement learning for scooping grasps with a robotic hand, using fingertip force
feedback to compensate for low mechanical stiffness.
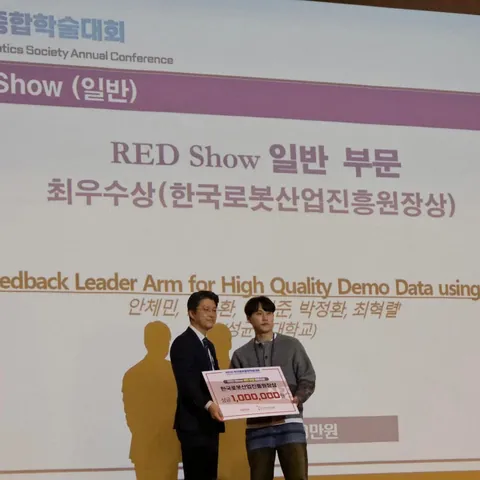
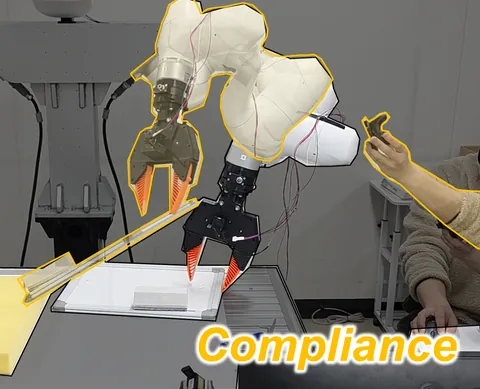
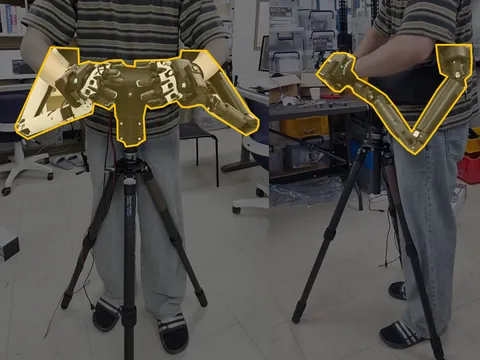
Bilateral teleoperation of a dual-arm robot and robotic hands with gravity-compensated leader arms and force feedback.
This work achieved 1st place at the
RED Show, KRoC 2026.